Overview
Team Durbar was formed to build a Mars rover for the University Rover Challenge (URC). As a founding member, I helped develop the rover at Khulna University of Engineering & Technology, contributing to its mechanical design, control system, and manipulator arm.
The team project combined rough-terrain mobility, remote manipulation, and an in-situ testing unit for analyzing soil and air properties.
Rover Design
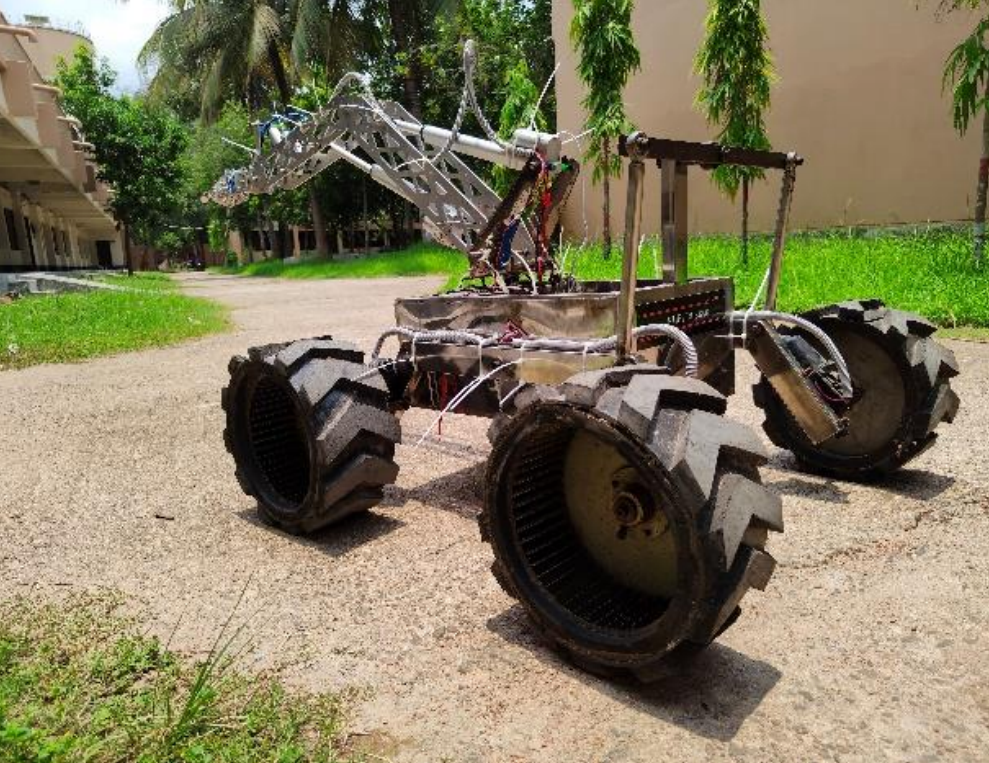
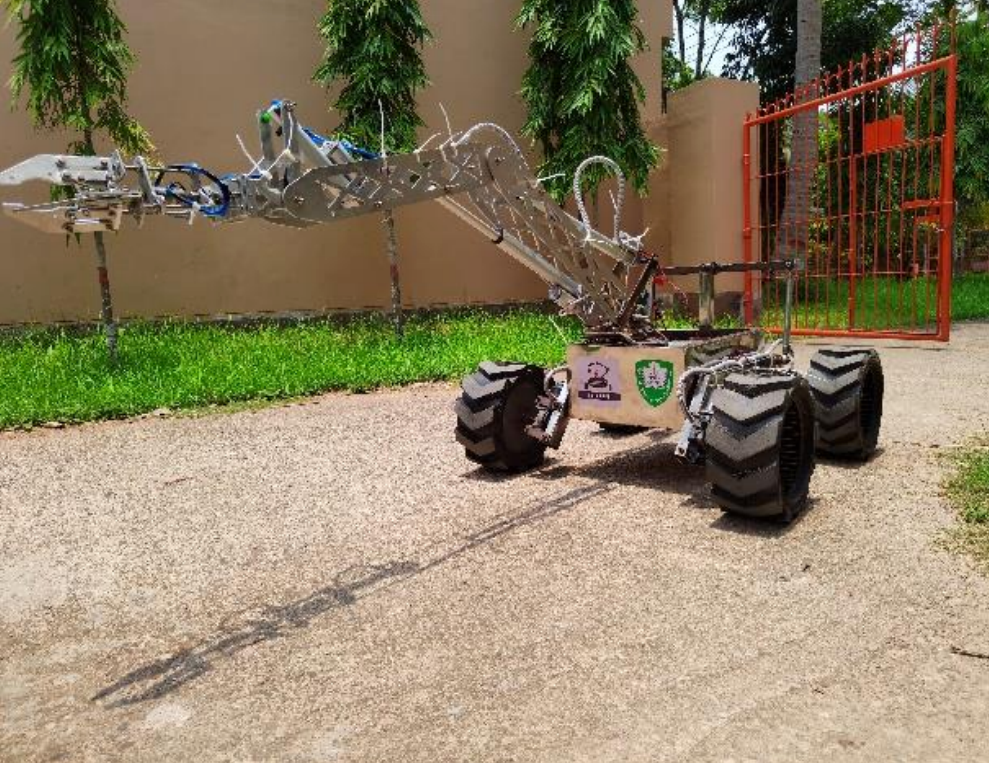
The rover's chassis was constructed from stainless steel square pipes. A rocker-bogie mechanism enabled it to navigate rough terrain, while four high-torque motors drove custom-made wheels fitted with rubber tires for traction.
The manipulator arm was CNC-cut from aluminum sheets and used linear actuators as its primary mechanism. Designed for lifting loads of around 5 kg, the arm could be operated through either a radio transmitter or a base computer.
- Suspension
- Rocker-bogie
- Drive motors
- 4
- Arm lifting capacity
- ~5 kg
Control System
An Arduino Mega controlled the drivetrain and manipulator arm. A Raspberry Pi served as the master controller, handling decision-making and path planning, while omnidirectional antennas supported communication with the rover.
The rover also included an in-situ testing unit capable of autonomously analyzing soil and air properties.
My Contributions
- Led the design and construction of the rover using a rocker-bogie mechanism.
- Led the control system and software sub-team in developing and implementing the rover's drive system.
- Designed and constructed the manipulator arm for lifting approximately 5 kg.